01 / Mobile base + lift
Evaluate mobility on representative floors, braking, leveling, stability and reachable work envelope. Verify the raised assembly under load before overhead tooling tests.
Intelligence built
from real work.
A staged R&D direction for overhead positioning and drilling. Concept hardware is not a production robot or a claim of autonomous deployment.
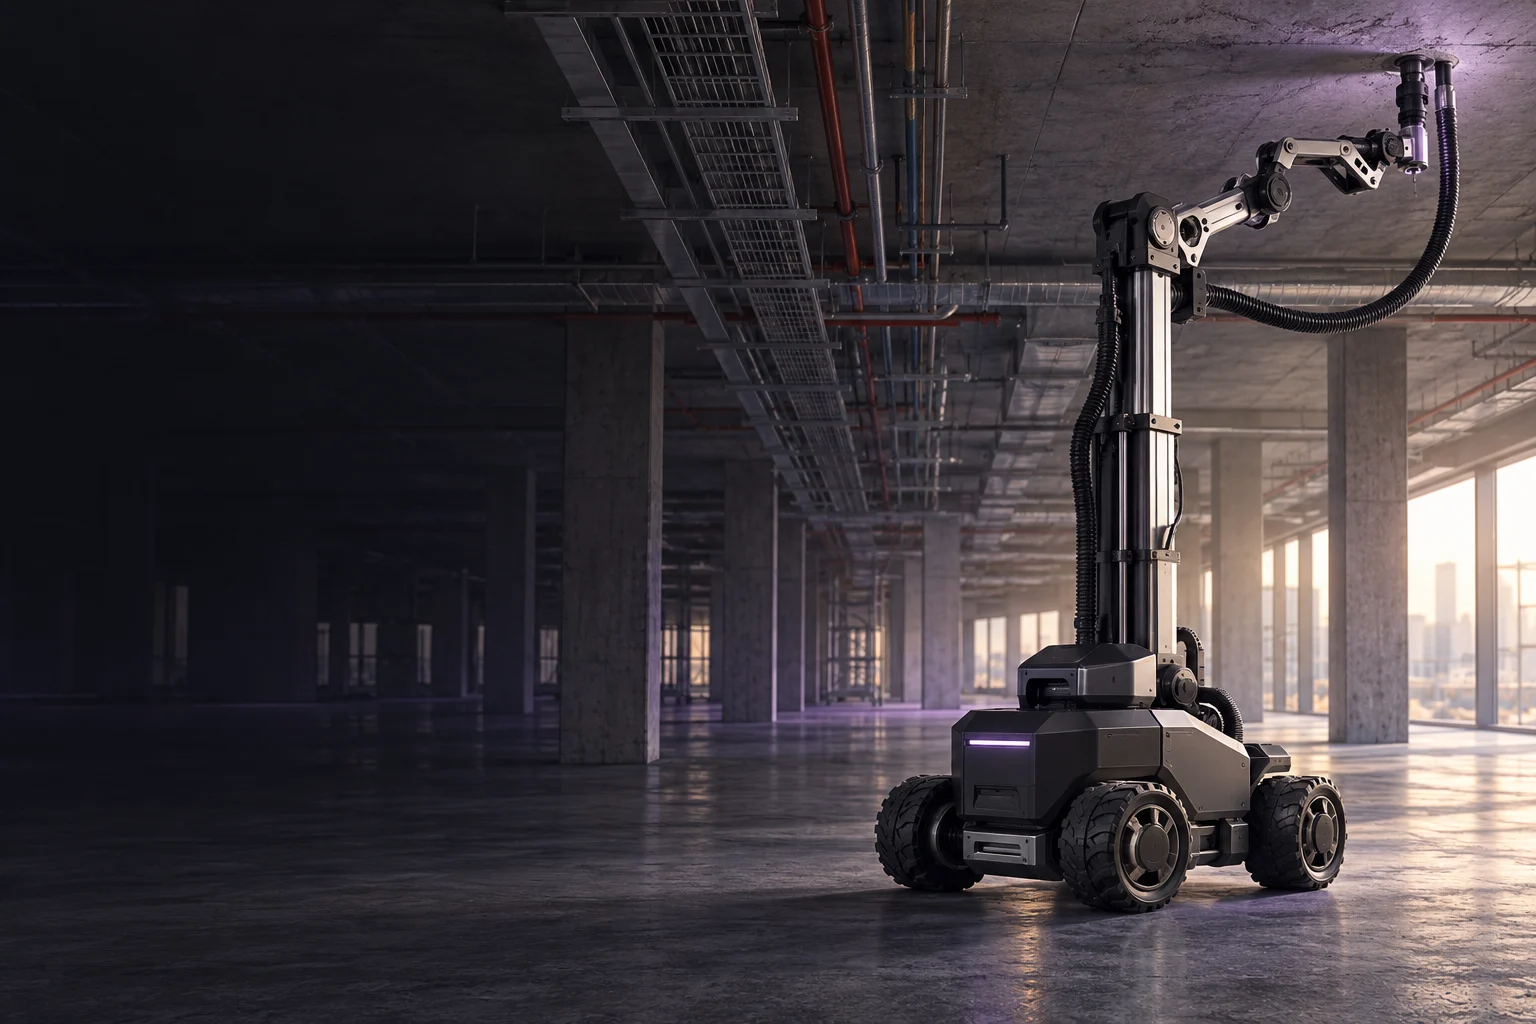
Evaluate mobility on representative floors, braking, leveling, stability and reachable work envelope. Verify the raised assembly under load before overhead tooling tests.
Research map registration, ceiling target detection and local end-effector alignment. Measure localization error and repeatability against surveyed targets rather than relying on a visual demo.
Develop supervised drilling with force limits, rebar or obstacle checks, dust extraction, emergency stop and safe retract. Test hole position, depth, completion rate and operator interventions under documented conditions.
Progress through bench tests, controlled mockups and authorized site pilots. Support-and-hanger installation is a future research extension requiring its own tooling, inspection and safety validation.