Capture
Commercial action cameras and IMUs, with site-safety review and worker participation.
Intelligence built
from real work.
Construction expertise. Structured data.
A measured path toward capable robots.
A precise movement. The right tool. A decision shaped by the site. We are building a way to turn professional construction knowledge into structured demonstrations for embodied AI research.
Our approach ↗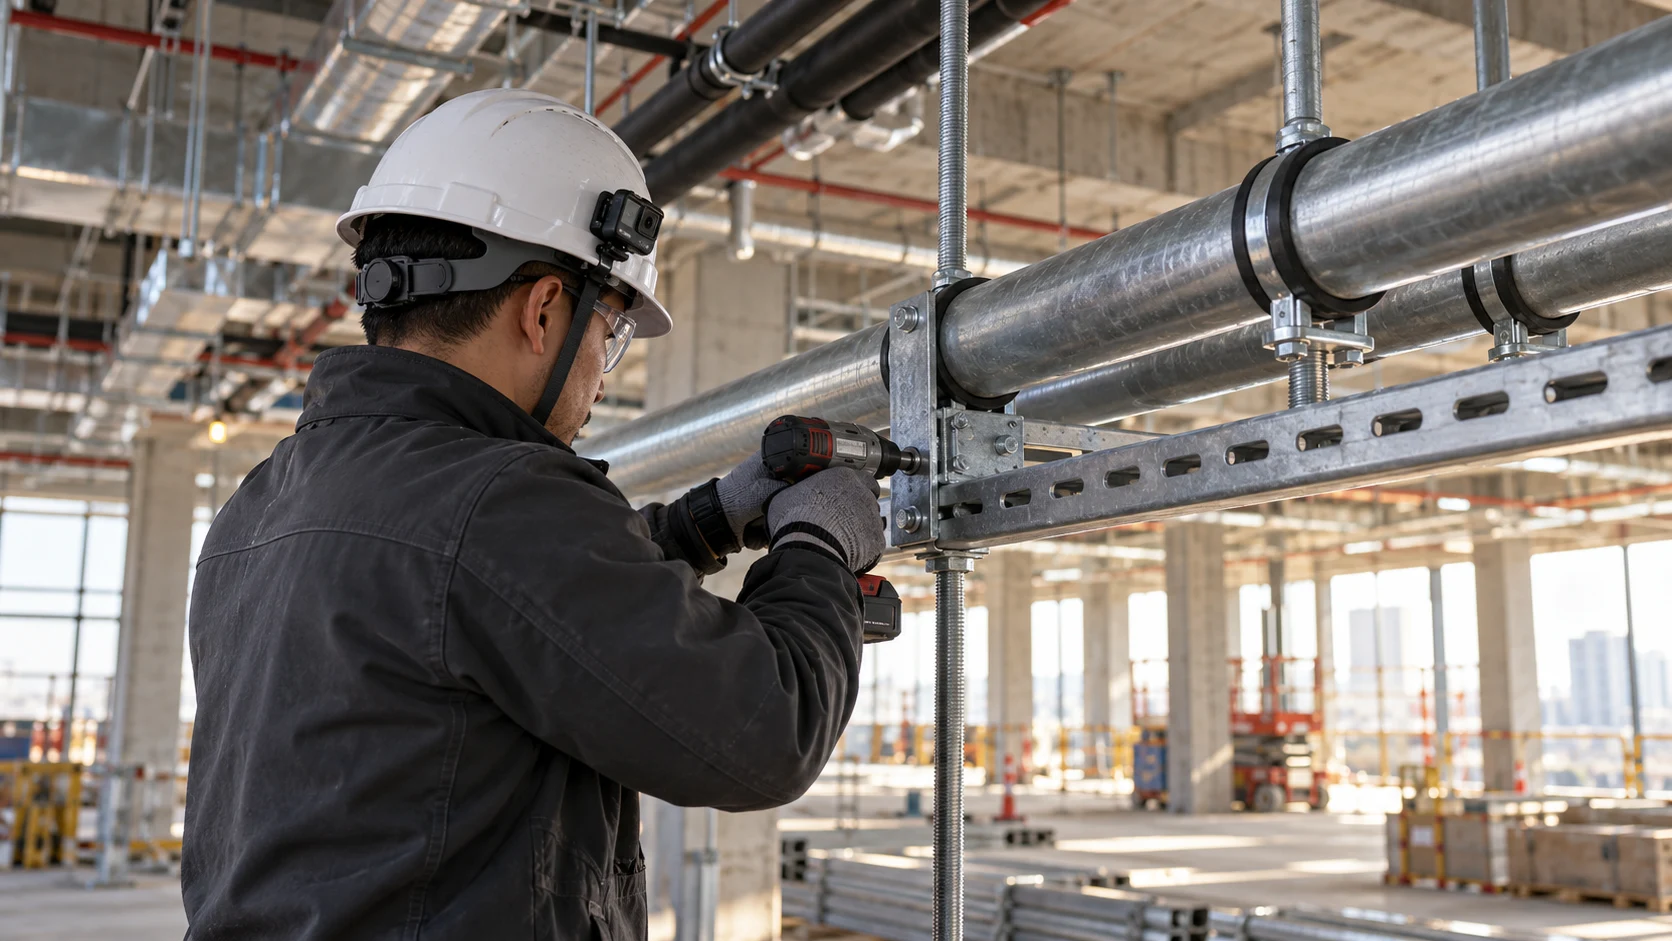
First-person video, commercial IMUs and available tool signals.
Collected with clear notice and informed authorization.
Commercial action cameras and IMUs, with site-safety review and worker participation.
A common timeline, calibration versions and checks for missing or drifting signals.
Task annotations, quality evidence and an agreed license, packaged with provenance.
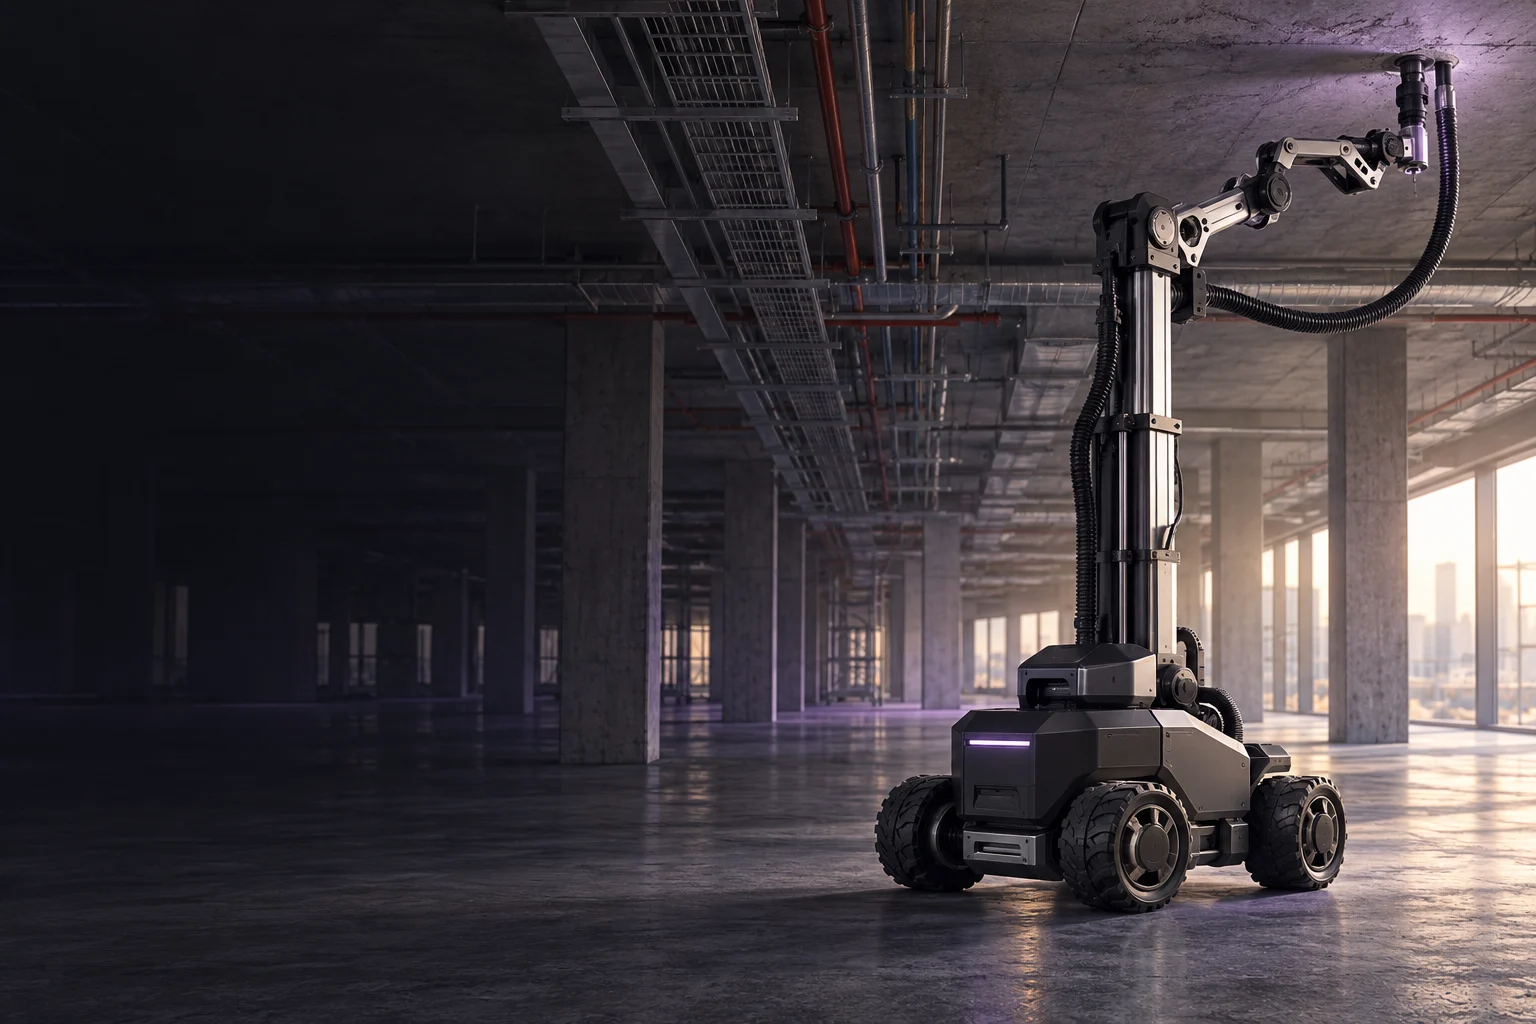
Mobility. Lift. Localization. Supervised drilling and dust extraction.
A development path, not a production claim.